





News date: September 24, 2026
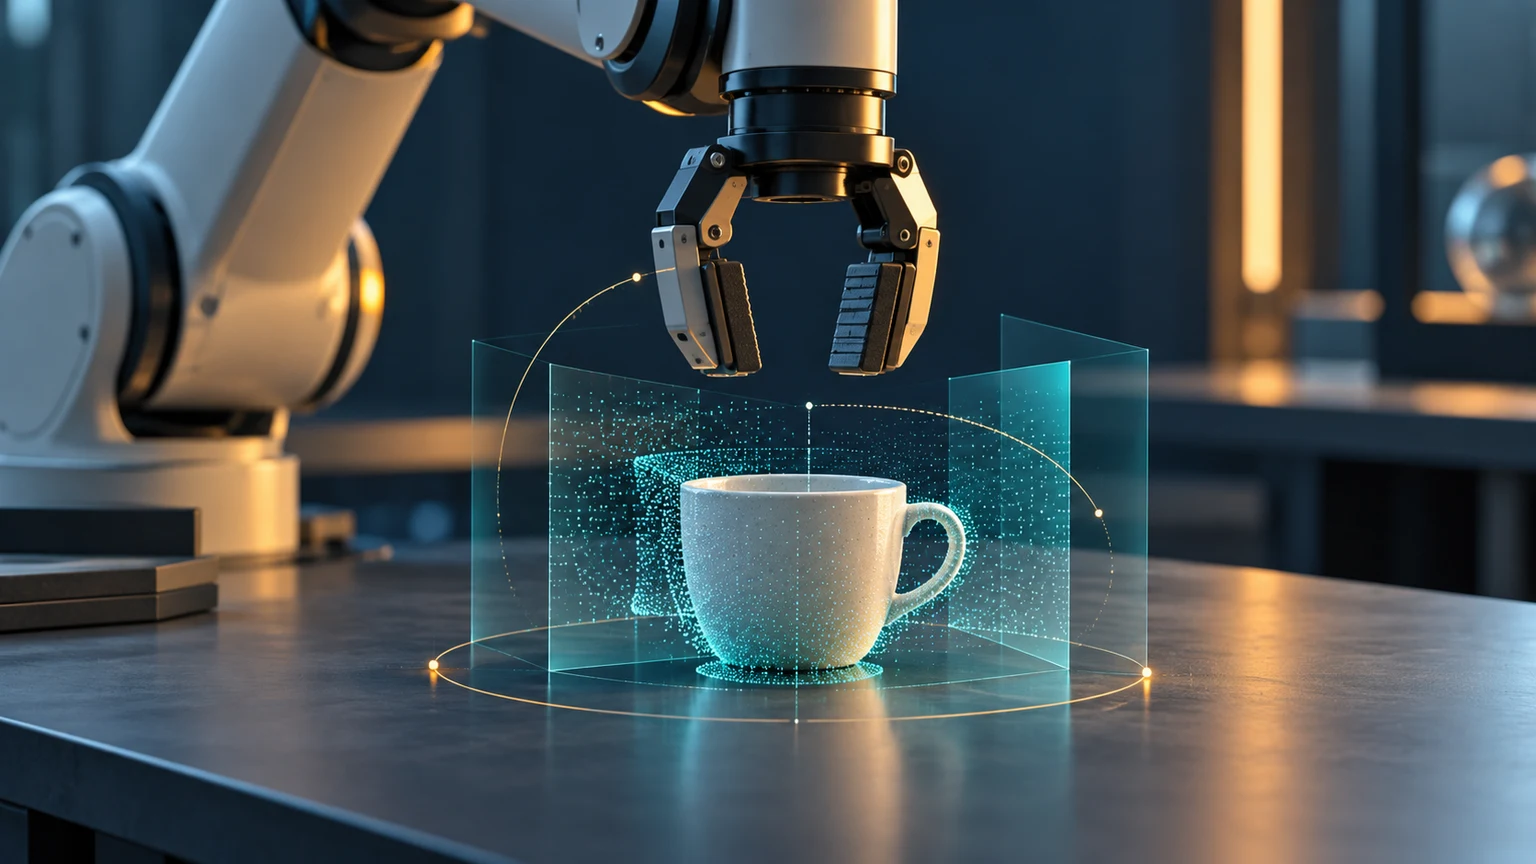
A research preprint submitted on September 24, 2026, introduces Robo-Harness K1, a framework that gives robot-controlling AI access to structured perception tools. The idea is to provide usable information about depth and object geometry before the model chooses an action, reducing its dependence on interpreting ordinary images alone. [1]
Testing the interface around the model
The authors report that Gemini 3.7 Flash with K1 reached 77.8% accuracy on matched LIBERO-PRO tasks. In their comparison, GPT-6 Astra with an RGB-only interface reached 61.1%, while Astra with K1 reached 88.9%. These figures describe the paper’s specific evaluation setup, not general success rates for commercial robots. [1]
A separate September 21 preprint provides useful context. Its RoboDojo evaluation found that Astra performed better on tasks involving semantic understanding than on precision, dynamic movement, or coordinated two-arm work. The studies use different benchmarks, so their scores should not be compared directly. Together, they highlight the importance of how models receive information and produce actions. [2]
What researchers still need to establish
Our interpretation is that better interfaces deserve attention alongside larger models. A robot may benefit from explicit distance measurements or grasp candidates because those tools reduce ambiguity at the moment it must move. That is a testable engineering idea, without assuming that a language model already understands every physical situation.
The next useful evidence would include independent reproduction and tests under changed lighting, clutter, sensor noise, and unfamiliar objects. Researchers would also need to measure response time and recovery after a failed action. A high score in one setup cannot establish those properties.
K1 is a research result reported in an arXiv preprint. It should be read as a promising method to investigate, with conclusions limited to the experiments described. It does not establish that general-purpose robot manipulation is solved.
Sources and credit
News facts are summarized from the original sources below. Commentary and assessment are original to this article.
Zhang and colleagues — early robot policy evaluation — Submitted September 21, 2026.below to be the first to hear when we reopen the doors to new students.
Li and colleagues — Robo-Harness K1 preprint — Submitted September 24, 2026.


